1st Place Winner, Project Demonstration — Koshi Yantra 3.0
Won 1st place and NPR 20,000 cash prize in the national Project Demonstration competition at Koshi Yantra 3.0 with our group project: an offline voice-controlled smart automation system featuring master-client architecture, voice talk-back, and walking robotic motion.
Certificate of Achievement — First Position in Project Demonstration
🏆 1st Position Winner · NPR 20,000 Cash Prize
Issuing Authority: Robotics Association of Nepal - EAST & Koshi Yantra 3.0 Committee
“Officially awarded First Position in the Project Demonstration competition at Koshi Yantra 3.0 for exceptional engineering in offline voice automation and interactive robotic motion.”
Credential Verification
This credential was officially issued to Nishant Sah following rigorous evaluation and hands-on participation. You can click on the certificate preview to view the authentic full-resolution document.
View Full ResolutionAbout this Event & Participation
In the Project Demonstration exhibition at Koshi Yantra 3.0 ('Biggest Robotics Festival in Koshi Province'), presented by Robotics Association of Nepal - EAST at Fujisan Sagarmatha Boarding School, Itahari-19, Bhawanipur, our engineering group showcased a distributed smart automation and interactive robotics system. Built with a decentralized master node and client node, the system allows users to control household appliances entirely through offline voice recognition — operating with zero reliance on cloud services or internet connectivity. For lifelike engagement, the robot talks back with audio confirmation and features synchronized physical motion, including left/right orientation and walking locomotion. The project earned 1st place alongside a cash prize of NPR 20,000.
Works Executed & Responsibilities
Architected a decentralized master-client wireless network linking central voice processing to distributed appliance switching nodes
Implemented edge offline speech recognition to enable private, low-latency device control without internet dependency
Integrated two-way audio talk-back feedback confirming user instructions and reporting appliance status
Constructed mechanical linkages and servo/motor kinematics for coordinated left/right rotation and walking locomotion
Delivered live competitive demonstration rounds to technical judges and industry evaluators
Skills & Competencies Gained
Event Gallery & Documentation Photos
Photographs, certificates, and on-ground captures from 1st Place Winner, Project Demonstration — Koshi Yantra 3.0.
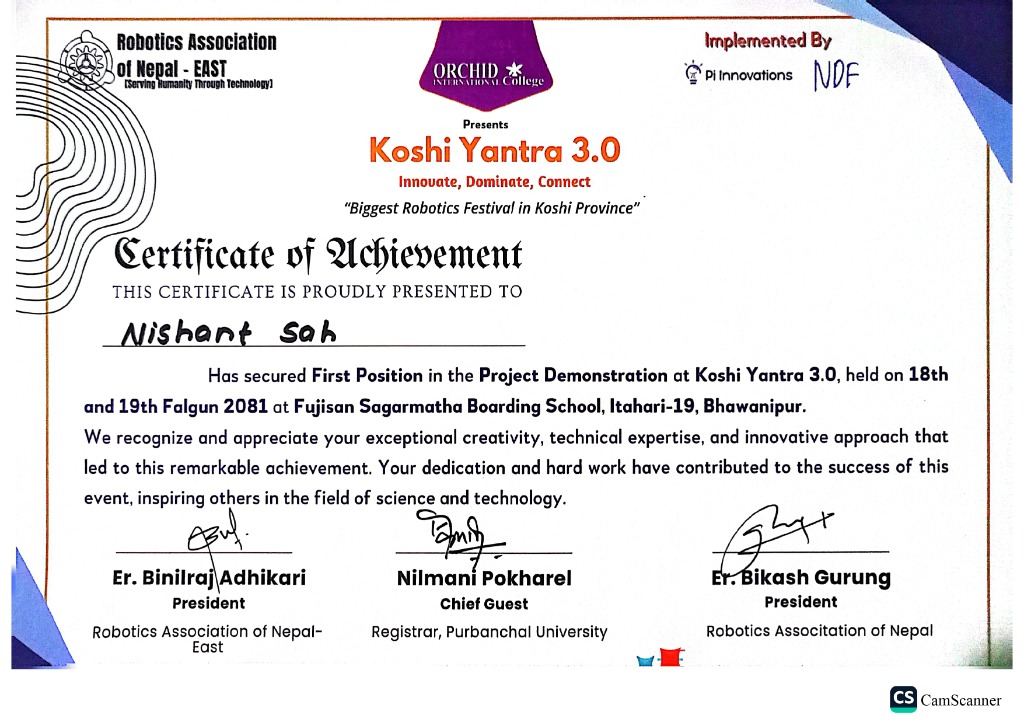
Official 1st Position Certificate of Achievement
Certificate of Achievement for securing First Position in Project Demonstration at Koshi Yantra 3.0.
Master & Client Offline Voice Demo
Live demonstration of offline voice recognition controlling client devices with real-time audio talk-back.
Locomotion & Walking Mechanism
Calibrating the interactive robotic node's left-right directional turning and walking locomotion.